A proportional term is the PID component whose control output scales with the current error: u(t) includes Kp e(t). If room temperature differs from its desired value, this term produces a corrective heater signal aimed at reducing the difference. section 8.7
Within PID control, the terms respond to different properties of error:
- The proportional term responds to the present error. section 8.7
- The integral term responds to error magnitude over time. section 8.7
- The derivative term responds to the rate at which error changes. section 8.7
Room-temperature control
A closed-loop controller compares the desired temperature with feedback from the room. The proportional component uses that difference to produce a heater control signal. Increasing Kp decreases rise time and steady-state error, but increases overshoot; settling time changes only slightly. section 8.7
Figure 8.17 PID-based closed-loop control system—the PID controller takes the error signal and produces a control signal to reduce the error to zero.
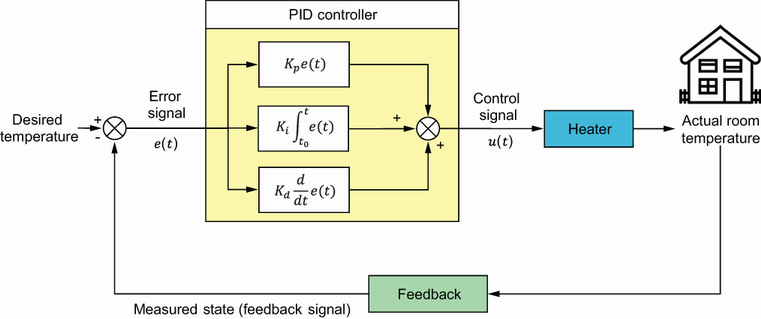
Trace the error signal from the desired state and feedback signal to the corrective control output. section 8.7
