ROS, used here to mean ROS 2, is an open-source robotics framework combining middleware, robot base libraries and services, development tools, reusable capabilities, and an active community. It connects robot applications with sensors, actuators, and algorithms through interoperable software components. section 4.0 section 4.1
A practical ROS system combines:
- Plumbing: communication protocols, common message types, and drivers for sensors and actuators. section 4.1
- Tools: RQt and RViz for visualization, Gazebo for simulation, rosbag2 for recording and playback, and ros2 for command-line scripting and introspection. section 4.1
- Capabilities: ROS-compatible sensing, planning, and acting implementations that serve as building blocks for robot applications. section 4.1
- Communication concepts: nodes exchange information through topics and services, providing concrete implementations of broader robot software concepts. section 4.0 section 2.0
ROS is useful both for realistic robot development and for learning transferable robotics ideas. Abstract APIs for hardware and software map onto ROS APIs, helping programmers move between ROS and other commercial or open-source robot stacks. section 1.4 section 2.0
Figure 4.1 The ROS equation illustrates how the combination of plumbing, tools, capabilities, and a global community makes the Robot Operating System the most popular open-source robotics software framework. [1]
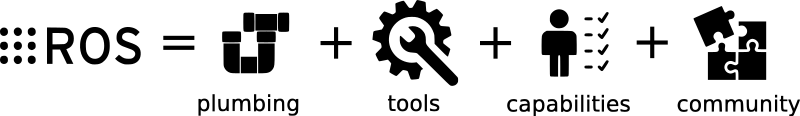
Use the ROS equation to relate plumbing, tools, capabilities, and community as parts of one robotics framework. section 4.1
