A sensor fusion algorithm combines measurements from multiple sensors to estimate a state or property more reliably than any individual measurement. In a robot software stack, it belongs primarily to sensing. section 2.2
Sensor fusion connects sensing with shared robot models. For example, encoder data can update a manipulator model in sensing, while acting reuses that model for control. section 2.2
Figure 2.6 The combined view of the horizontal and vertical subdivisions maps specific software components to their corresponding robot parts, showing how functions such as communication span parts, while others, such as navigation, are closely associated with specific parts.
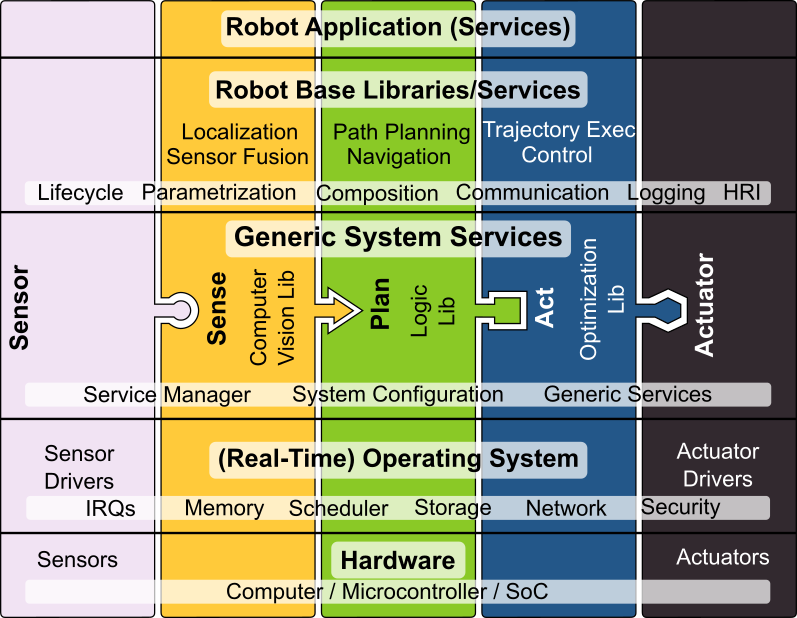
Map sensor fusion to sensing within the combined robot-system view, alongside navigation in planning and control in acting. section 2.2

