In Monte Carlo tree search, simulation completes a partial solution from an expanded node using a rollout policy, often random or greedy. The resulting outcome estimate helps compare paths without requiring perfect planning. section 7.5
Figure 7.4 The four-phase cycle of Monte Carlo Tree Search.
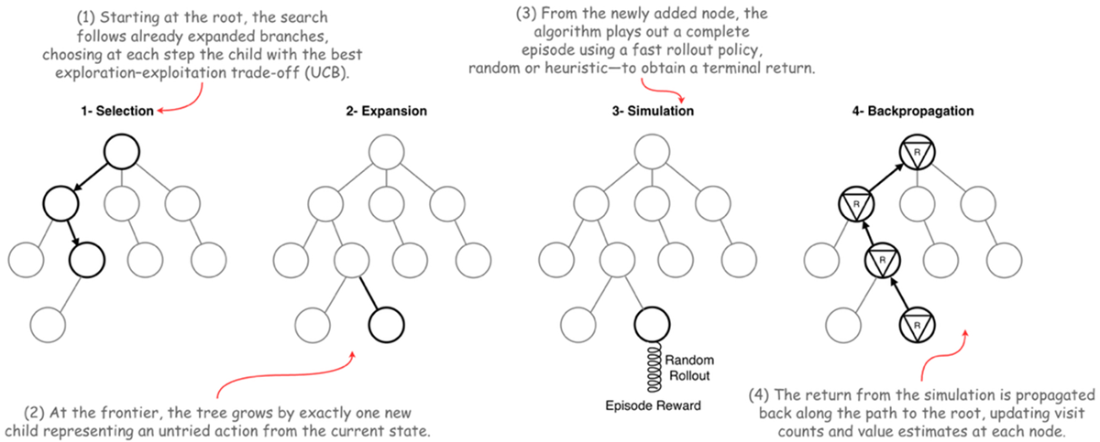
See how simulation fits into the repeating four-phase MCTS cycle. section 7.3
