Probability of Improvement (PoI) is a Bayesian optimization acquisition policy for expensive black-box objectives. At each iteration, it scores each candidate by the chance that its predicted objective value will beat the current incumbent, then queries the candidate with the highest score. section 4.0 section 4.2.2
For a maximization problem, improvement means exceeding the best observed value. A Gaussian process supplies a normal predictive distribution at each candidate; PoI is the area of that distribution above the incumbent threshold. Equivalently, compute one minus the normal CDF at the incumbent, using the predictive mean and standard deviation. section 4.2.2
Figure 4.11 Flowchart of how the PoI score is computed. By following this procedure, we can compute how likely any candidate point is to be able to improve from the incumbent.
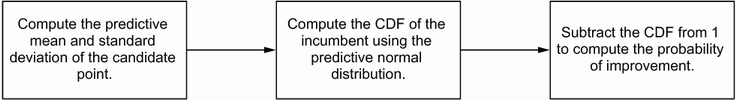
Follow the score from a candidate’s GP prediction through its normal-distribution tail area to its probability of improving on the incumbent. section 4.2.2
Use PoI in the optimization loop as follows:
- Fit a Gaussian process to the observations collected so far and identify the best observed objective value. section 4.5
- Construct PoI with that incumbent as its improvement threshold, score candidate inputs, and maximize the acquisition score. section 4.2.2 section 4.5
- Evaluate the selected input, add its label to the data, and repeat until the available function-evaluation budget is exhausted. section 4.2.3
PoI favors any positive improvement, however small. That makes it risk-averse and prone to exploitation: it can repeatedly sample a promising local region rather than inspect uncertain regions that may contain a better optimum. Raising the required improvement by ε makes the policy more exploratory, but choosing an appropriate threshold can be difficult across objectives. section 4.2.3 section 4.4.1
Escaping a local optimum
On the one-dimensional Forrester function, unmodified PoI remains between 0 and 2 and converges near a local optimum, missing the global optimum around 4. Setting a minimum improvement threshold, such as ε = 0.1, changes which candidates qualify as improvements and can improve exploration. section 4.2.3 section 4.4.1
In BoTorch, create an analytic ProbabilityOfImprovement policy with a model and best_f equal to the incumbent, then pass it to optimize_acqf() to locate the next query. For a batch, the improvement event is defined by whether the best objective value among batch members exceeds the incumbent. section 4.2.2 section 7.2.1
