Raw data are uninterpreted measurements produced directly by robot sensors. Sensors measure physical quantities and expose those measurements to the robot software; sensing gives them meaning so planning can use them to pursue objectives. section 1.2.3 section 3.1
A basic robot system treats raw data as the first stage of an information pipeline:
- Sensors produce measurements from the environment. section 3.1
- Sensing processes those measurements into meaningful information. section 3.0 section 3.2
- Planning uses the resulting information to choose actions directed toward robot objectives. section 1.2.3
The ReBo(o)t light sensor
A robot that automatically reboots a crashed computer can use a light sensor and one actuator. Directly using the light sensor’s raw data may be acceptable for this toy robot, but real systems should place sensor-data processing inside a dedicated sensing component rather than connecting sensors directly to planning. section 3.1 section 3.2
Figure 3.1 The ReBo(o)t is a simple robot consisting of a single light sensor and actuator that automatically reboots a crashed computer.
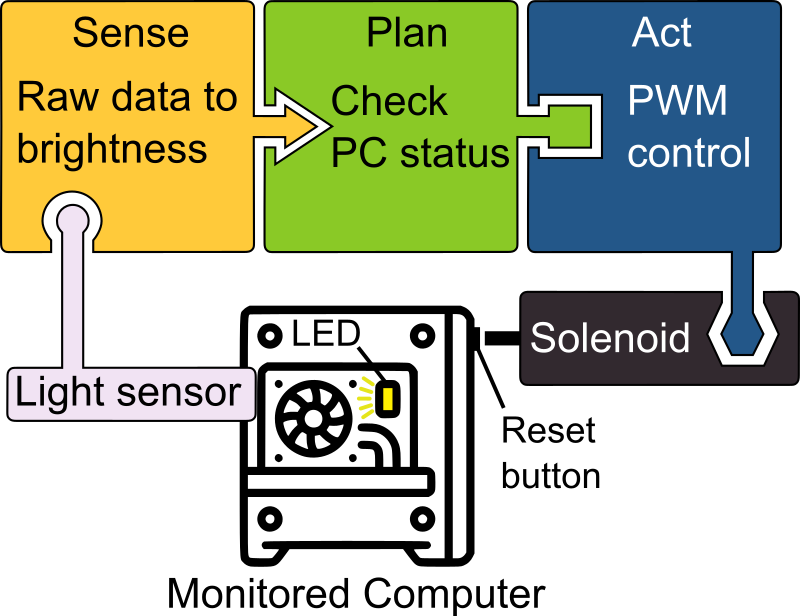
Shows the simple sensor–actuator structure of the ReBo(o)t example. section 3.1

