liveBook · Manning

Operating system

As explained in Robotics for Programmers

An operating system is system software that manages hardware resources and provides fundamental services and interfaces for application programs.

An operating system (OS) is the robot software-stack layer that manages hardware resources and supplies common services to higher-level software. It uses drivers to expose a unified API across similar devices, while providing multitasking, memory management, data storage, and networking. section 2.2

In a robot system, the OS:

  • Manages hardware devices beneath generic services and robot-specific software. section 2.2
  • Provides drivers that give similar hardware devices a unified programming interface. section 2.2
  • Supports general mechanisms such as multitasking, memory management, storage, and networking. section 2.2
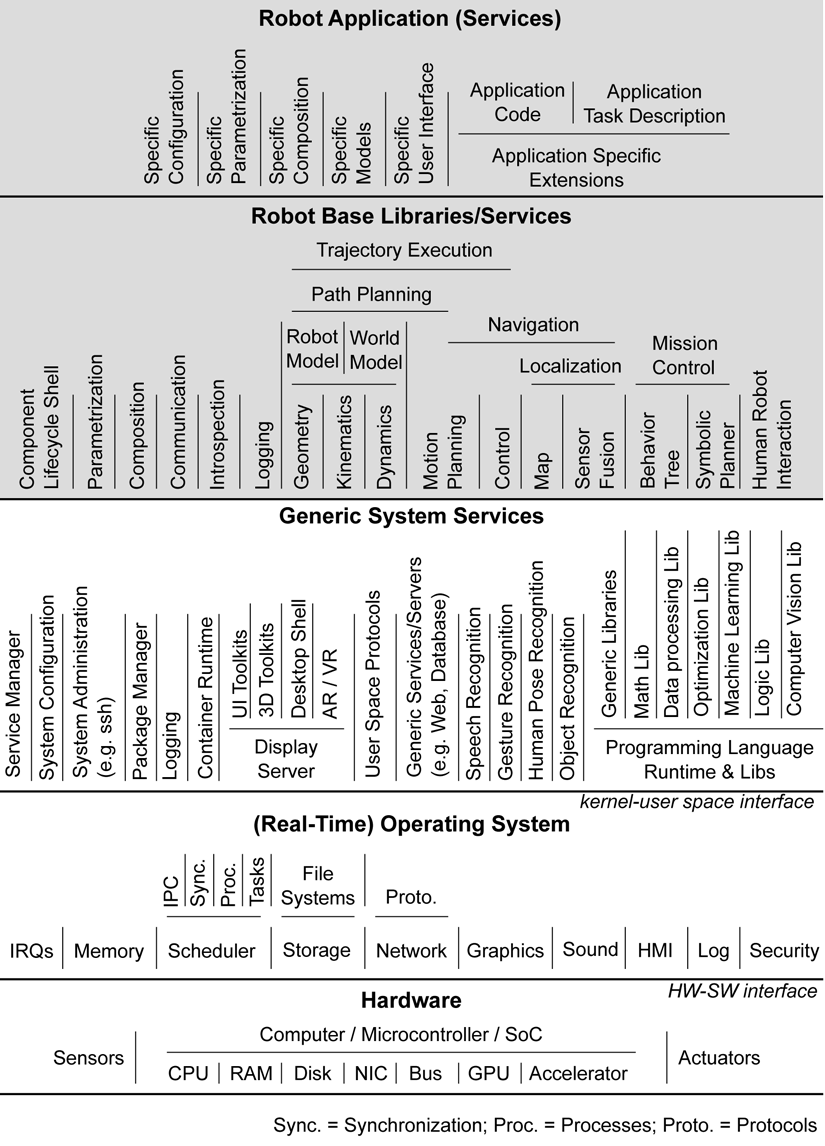
Figure 2.5 The robot software stack illustrates the vertical subdivision of robot systems, from hardware to the application layer, highlighting the base and application layers that are specific to robotics.
CH02 Fxx bihlmaier robot software stack

The robot software stack places the OS between hardware and generic services, robot base libraries, and applications. section 2.2


How Robotics for Programmers covers it

How deep it goes
Defines hardware management, drivers, multitasking, memory, storage, and networking without descending into implementation internals.
Examples
Uses unified hardware APIs, multitasking, memory management, data storage, networking, and software execution as representative OS functions.
What it assumes
Assumes familiarity with general software-system layers while establishing the OS role in robot software.
What you can do after
Evaluate robot architectures by locating hardware interfaces, generic services, and applications around the operating-system layer.
How it connects
Connects hardware devices, drivers, generic services, robot base libraries, and application software.

Also explained in

Compare how 5 books explain operating system →

Related concepts

This explainer was generated by Manning's knowledge graph from the text of Robotics for Programmers. The section links point to the parts of the book it draws on.


