A scheduler determines which tasks execute and when. In embedded real-time systems, it works with task priorities and preemption to help computations finish before their deadlines. section 3.5
Priority-based preemption
A higher-priority real-time task can pause a running lower-priority task, execute temporarily, and allow both tasks to meet their deadlines. section 3.5
Figure 3.14 Preemptive scheduling ensures temporal correctness by allowing a higher-priority real-time task to pause and temporarily replace a running lower-priority task, ensuring both tasks meet their execution deadlines.
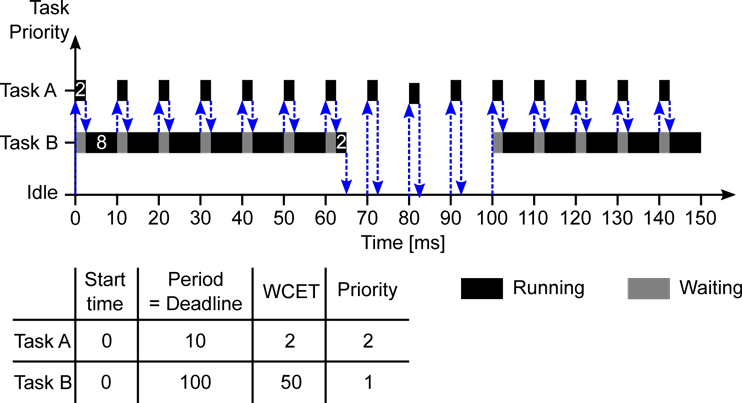
Visualizes how preemptive scheduling replaces a lower-priority task with a higher-priority task to preserve temporal correctness. section 3.5