A feature map represents input objects as vectors in a feature space, which may be infinite-dimensional. In convolutional neural networks, a trainable kernel slides across an input, computes a dot product at each position, and gathers the resulting scalars into a feature-map output. section 10.2 section 6.5
Feature maps serve two related purposes:
- Expose local responses to learned filters while preserving translation-related structure in image, time-series, or volumetric inputs. section 10.2
- Provide a transformed space in which inner products can be replaced by kernel evaluations, avoiding explicit vector construction. section 6.5
- Shrink spatial dimensions through pooling while increasing learned feature channels across stacked convolutional layers. section 10.2.1
LeNet feature maps for MNIST
A LeNet-style classifier applies convolution, ReLU activation, and max pooling repeatedly. It learns more features by increasing the number of filters, reduces feature-map dimensions through pooling, then flattens the final map before a dense softmax classifier. The implementation trains and evaluates the model on MNIST. section 10.2.1
(10.8)
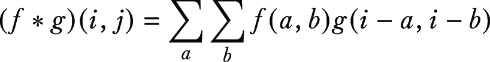
Use the convolution figure to trace how sliding-kernel dot products become a feature-map output. section 10.2







