Ground truth is the complete actual state of a modeled or physical world. In robotics simulation, it is the simulator’s authoritative state, updated by physics, user inputs, and robot commands. section 5.1
A robot cannot directly observe ground truth. It instead builds an incomplete estimated state, or belief world, from sensor data and prior knowledge. A depth camera may reveal only the fronts of boxes, while the simulator knows their complete shapes and locations. section 5.1
Gazebo and RViz
Gazebo displays the simulated world’s ground truth, including complete boxes on shelves. RViz displays the robot’s estimated state and virtual sensor data, which may show only visible surfaces. section 5.1
Figure 5.5 The Gazebo GUI (left) displays the actual state, or ground truth, of the simulated world, including complete boxes on shelves, while RViz (right) visualizes the robot’s incomplete estimated state based solely on what its virtual RGBD camera observes.
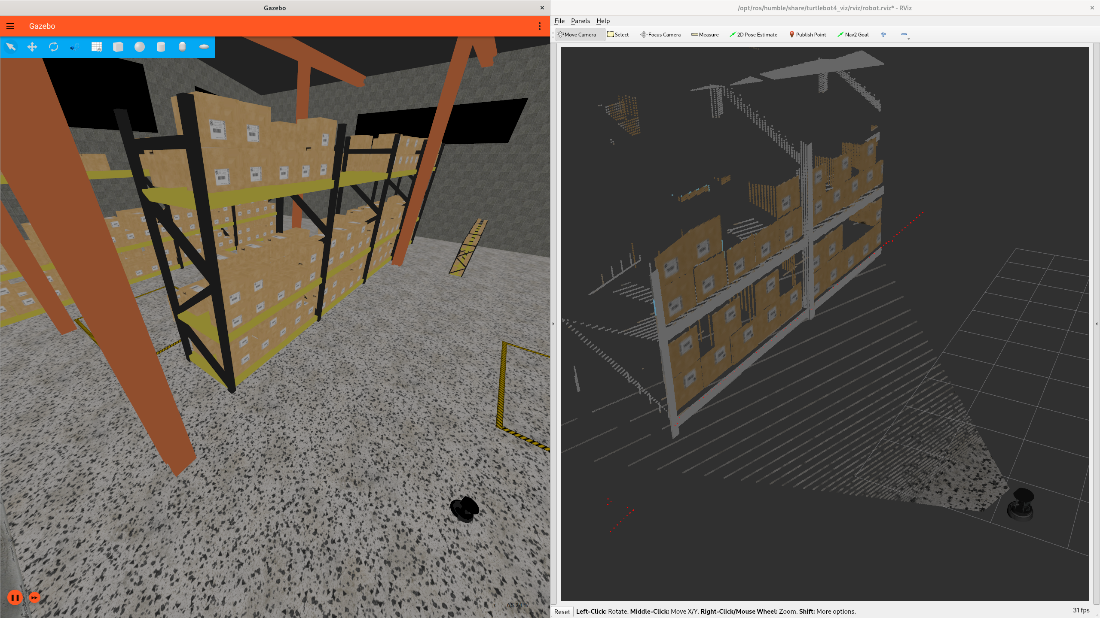
Compare the complete simulated world in Gazebo with the robot’s incomplete RGBD-based reconstruction in RViz. section 5.1




























